Anti-UAV Detection
Detect, classify, and track UAVs in RGB images and video through a full computer vision workflow.
- Problem
- UAV detection needs training discipline, tracking, and a usable app, not just a model.
- What I built
- A drone detection and ByteTrack tracking system with MLflow and a Streamlit app.
- My role
- Project author: detection and tracking pipeline, model comparison, MLflow, app.
- Result
- README video shows UAV detections with track IDs on an RGB drone clip.
Evidence
More recorded proof
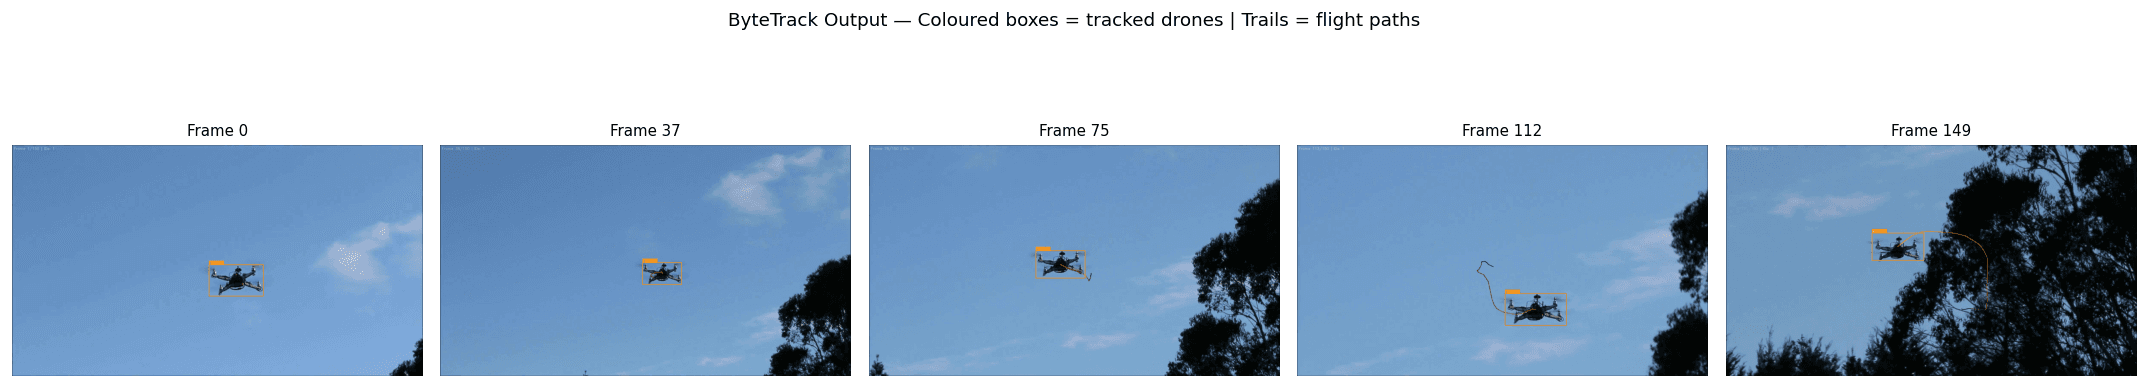
ByteTrack sample frames
Repository-provided RGB frame sequence showing ByteTrack UAV detections and track paths.
Problem
What this project had to solve
Real-time UAV detection is not just a model-selection problem. It also needs training discipline, model comparison, tracking, and a way to inspect outputs through an actual application workflow.
Role / contribution
What I owned in the system
Project author responsible for the detection/tracking pipeline, model comparison setup, MLflow tracking, Streamlit application path, and CI/CD structure described in the repository.
Architecture flow
System flow from input to output
Dataset preparation
What happens
Detection data is organized and split for repeatable training and evaluation.
Why it matters
Repeatable data splits are necessary before model comparisons and tracking results can mean anything.
Engineering decisions
Tradeoffs that shaped the build
Decision 01
Compare architectures explicitly
The project keeps one-stage and transformer-based detectors in the same evaluation story instead of assuming a single model choice.
Decision 02
Include tracking as part of the system boundary
Tracking is treated as a product requirement rather than a separate bonus experiment.
Decision 03
Wrap the repo in MLOps structure
Configs, tests, MLflow, Docker, and CI/CD make the pipeline inspectable and repeatable.
Technical implementation
How the system is built
The RGB-only training pipeline compares YOLOv11-S and RT-DETR-R50 with YOLOv8-M as the baseline, using organized configurations for reproducible experiments.
ByteTrack is integrated so the project covers tracking behavior instead of limiting itself to frame-level detection.
MLflow, Docker, tests, and GitHub Actions push the repository toward a full MLOps workflow rather than a single-model demo.
Stack
Core tools and system layers
Limits and next steps
What is not done yet
- Add broader scenario coverage beyond the current single-class framing.
- Training is RGB-only; IR/thermal use requires domain adaptation or retraining before those inputs can be supported.
- Tighten model-promotion and deployment criteria around tracked evaluation results.
Project explainer
Ask about this project
A case-study guide to the architecture and decisions behind Anti-UAV Detection.